
=== HEADLINE ===
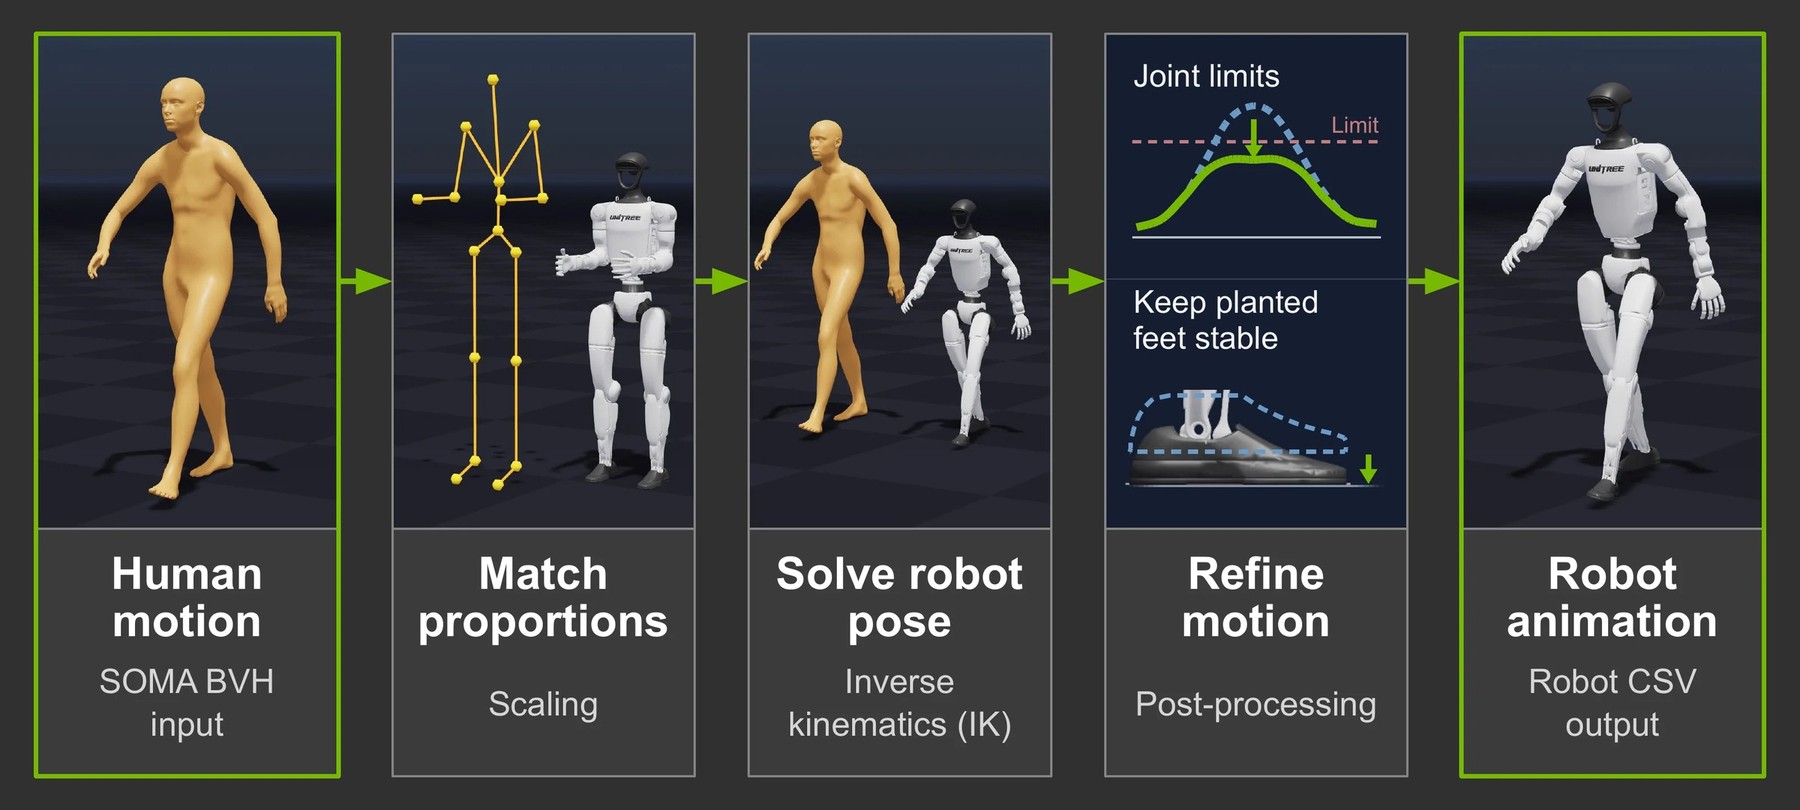
Figure 1. The retargeting pipeline converts SOMA BVH motion into robot joint trajectories through scaling, inverse kinematics, and post-processing. Across many clips, the resulting animations can form a motion library for downstream reference preparation and policy training.
Source: developer.nvidia.com
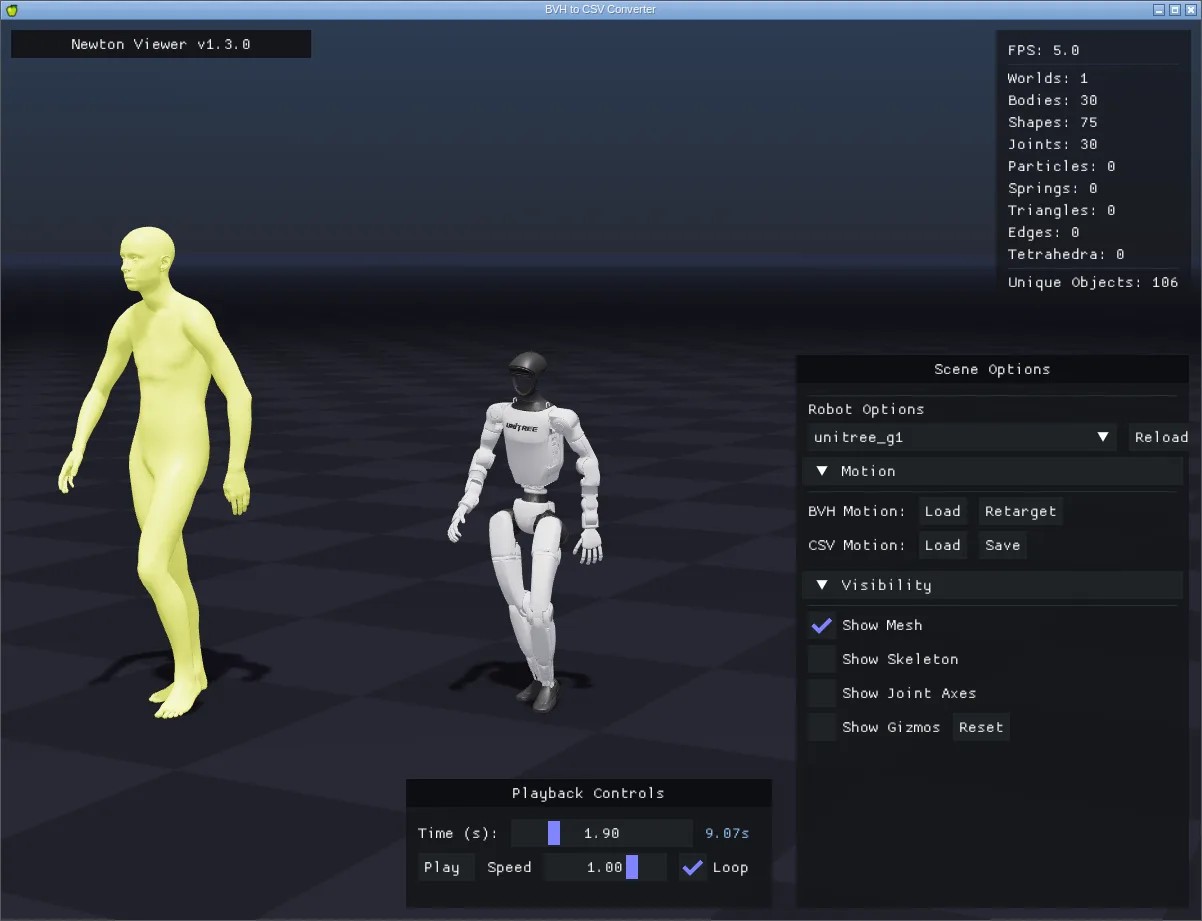
Figure 2 . The BVH to CSV Converter displays the human source motion alongside the retargeted Unitree G1 motion, with controls for loading, retargeting, and saving the result.
Source: developer.nvidia.com
Figure 3. The source motion is a one-handed wave, but an unaligned reference pose makes Booster T1 hold both arms outward (left). After aligning the robot’s reference pose with the SOMA human reference, one hand waves beside its head while the other arm rests at its side (right). Both panels use the same input motion and IK settings, isolating the effect of reference-pose alignment.
Source: developer.nvidia.com
Figure 4. Experimental adaptation of human motion for MicroDuck and training of a motion-tracking controller. Left: SOMA Human Motion. Middle: SOMA Retargeting. Right: Trained controller in Isaac Lab and Newton.
Source: developer.nvidia.com
Figure 5. MotionBricks generates continuous motion for a SOMA human and Unitree G1 robot in the reference demos, with recent motion and target poses shown alongside each character.
Source: developer.nvidia.com
NVIDIA introduces a tool for transferring human motion to robots
Daily AI news
Every day we pick what actually matters in AI and explain it plainly — no hype, no filler. Subscribe if you want to follow where the industry is going.
Only what matters — every day
Follow on X